For robotics
Real-time visual and spatial understanding for robotics.
Bring real-time VLM inference to robots that need to understand their surroundings and interact with objects. Connect language instructions with scene understanding and affordance reasoning to inform object selection, grasp planning, placement, and task verification.
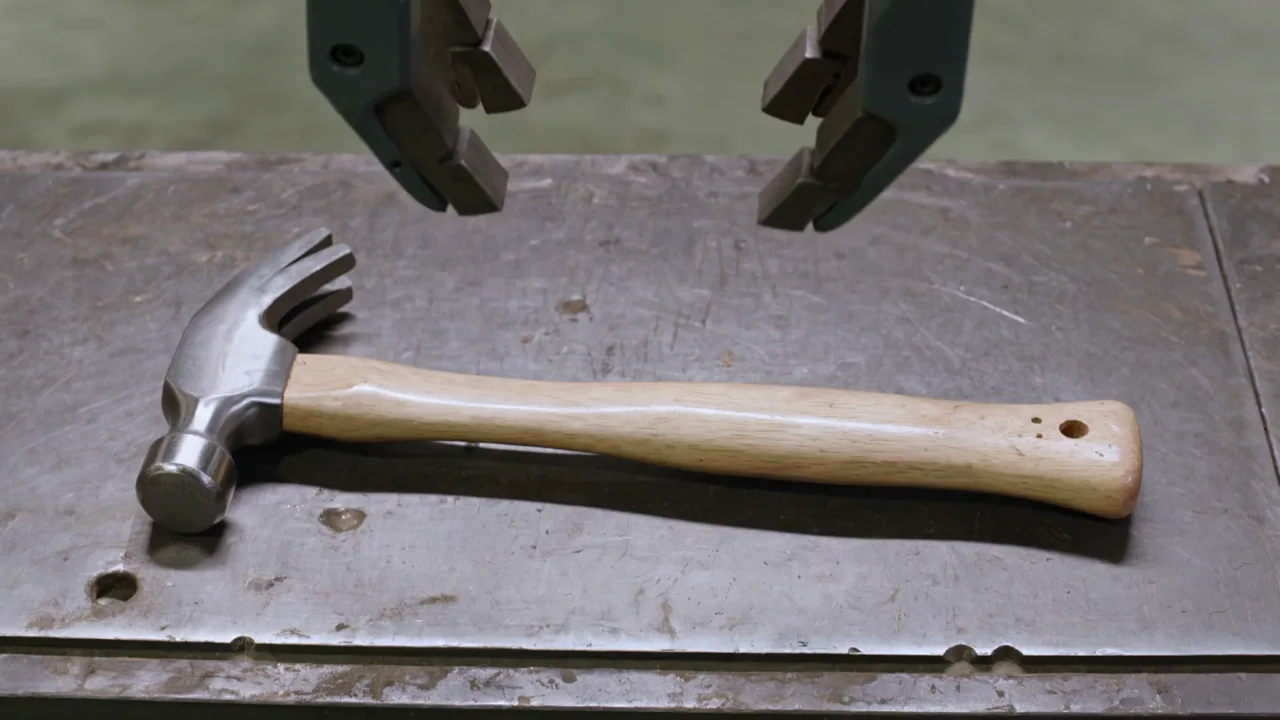
- Tool handle
Identify the part used to hold and operate the tool.
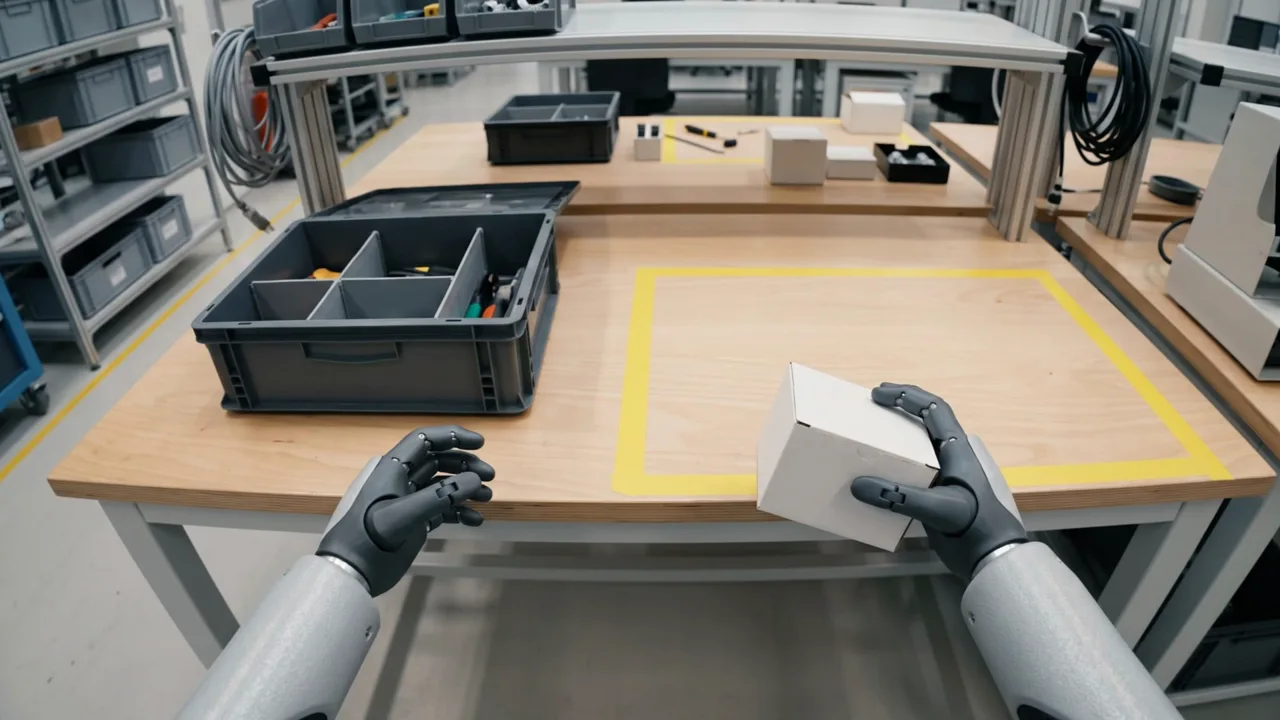
- Package surfaces
Consider opposing surfaces as candidate grasp regions.
- Placement area
Relate the object to its intended destination.
Highlighted regions show interaction context.
From perception to interaction
Understand the scene in the context of the task.
Spatial reasoning
Affordance reasoning
Task verification
From what the robot sees to what it does.